2025
Safe Fingers - Hand Rehabilitation Manipulator System
A hand rehabilitation manipulator system that combines polymer manipulators, torque and angle sensors, parameterized imitation learning and a basic rehabilitation software platform for safer, more personalized therapy support.
Project Notes
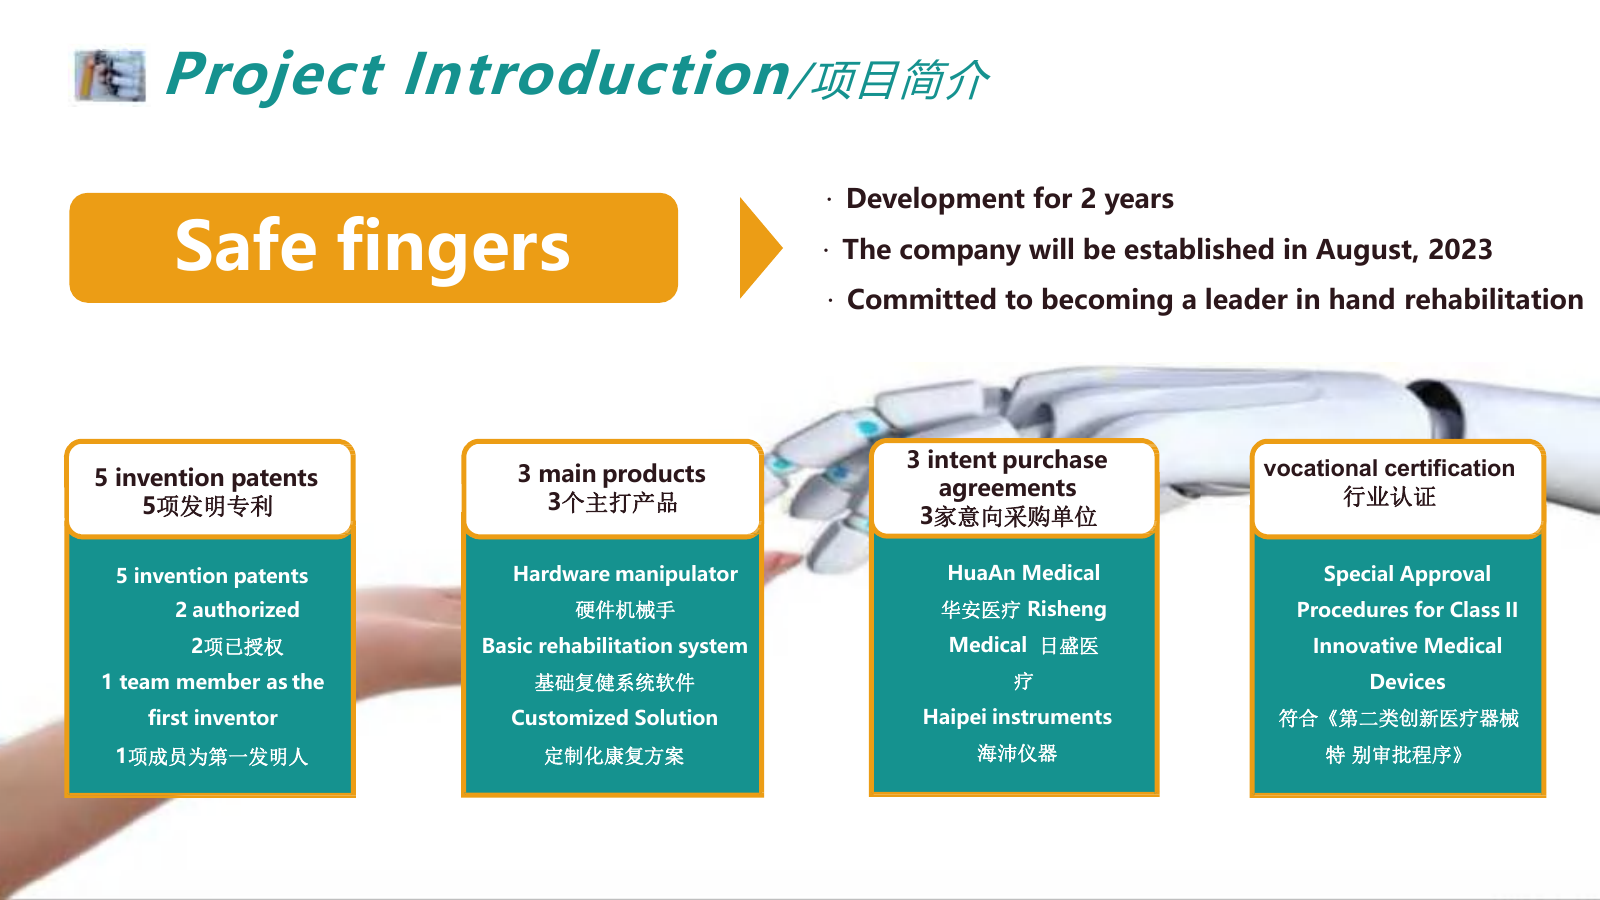
- The PDF presents Safe fingers as an undergraduate creativity and innovation project developed around hand rehabilitation.
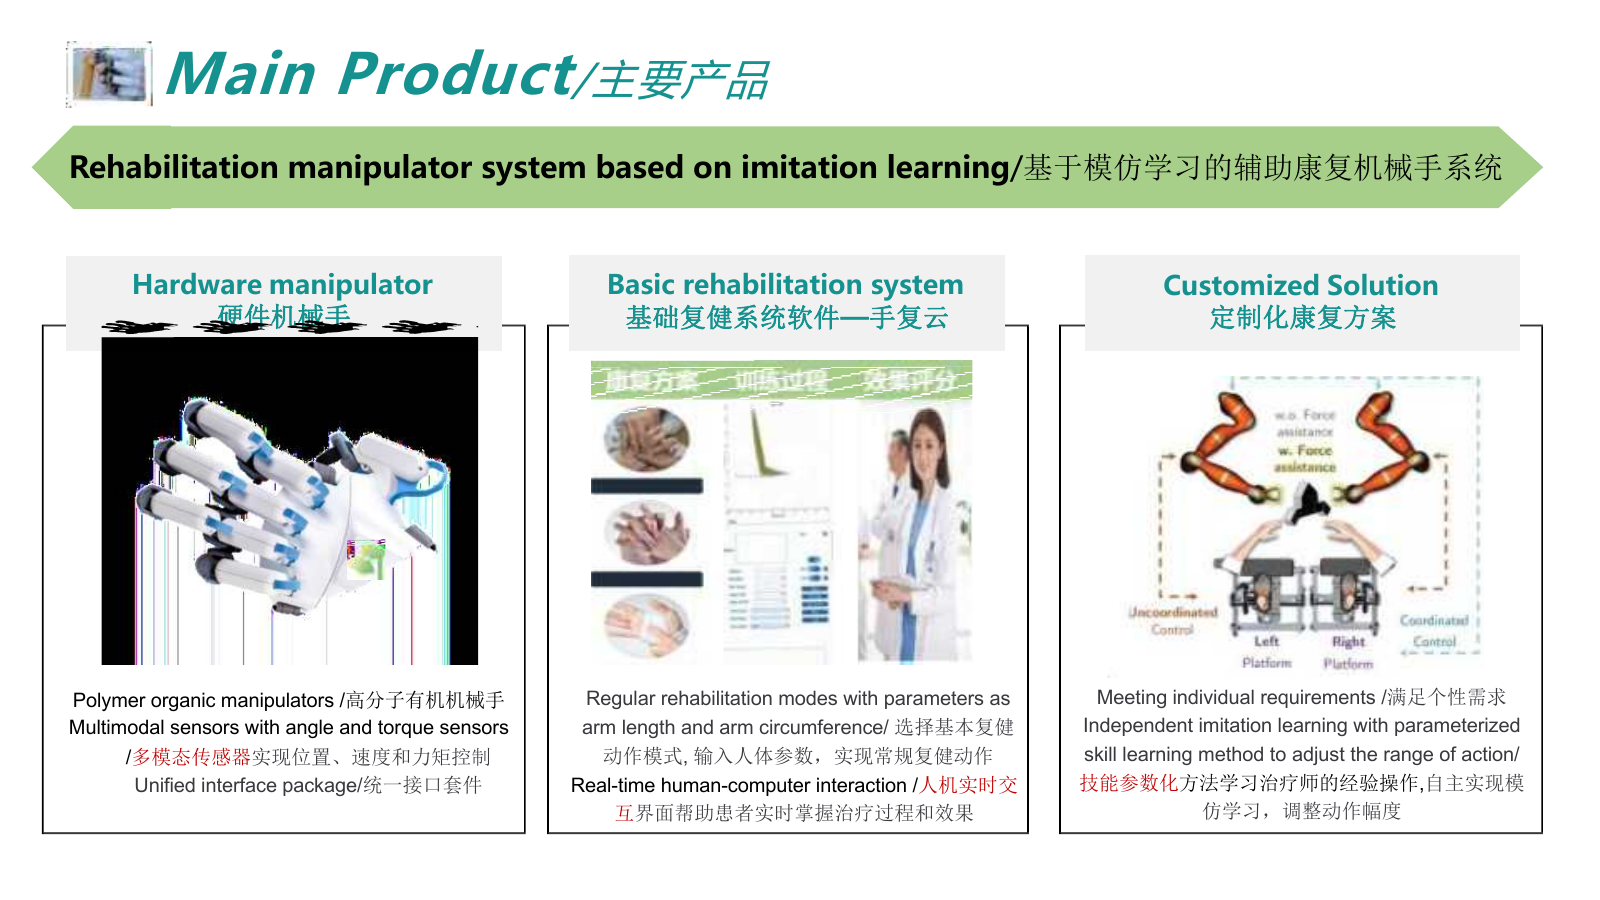
- The proposed system includes three product layers: a hardware manipulator, the basic rehabilitation software platform 'Shoufu Cloud', and customized rehabilitation solutions.
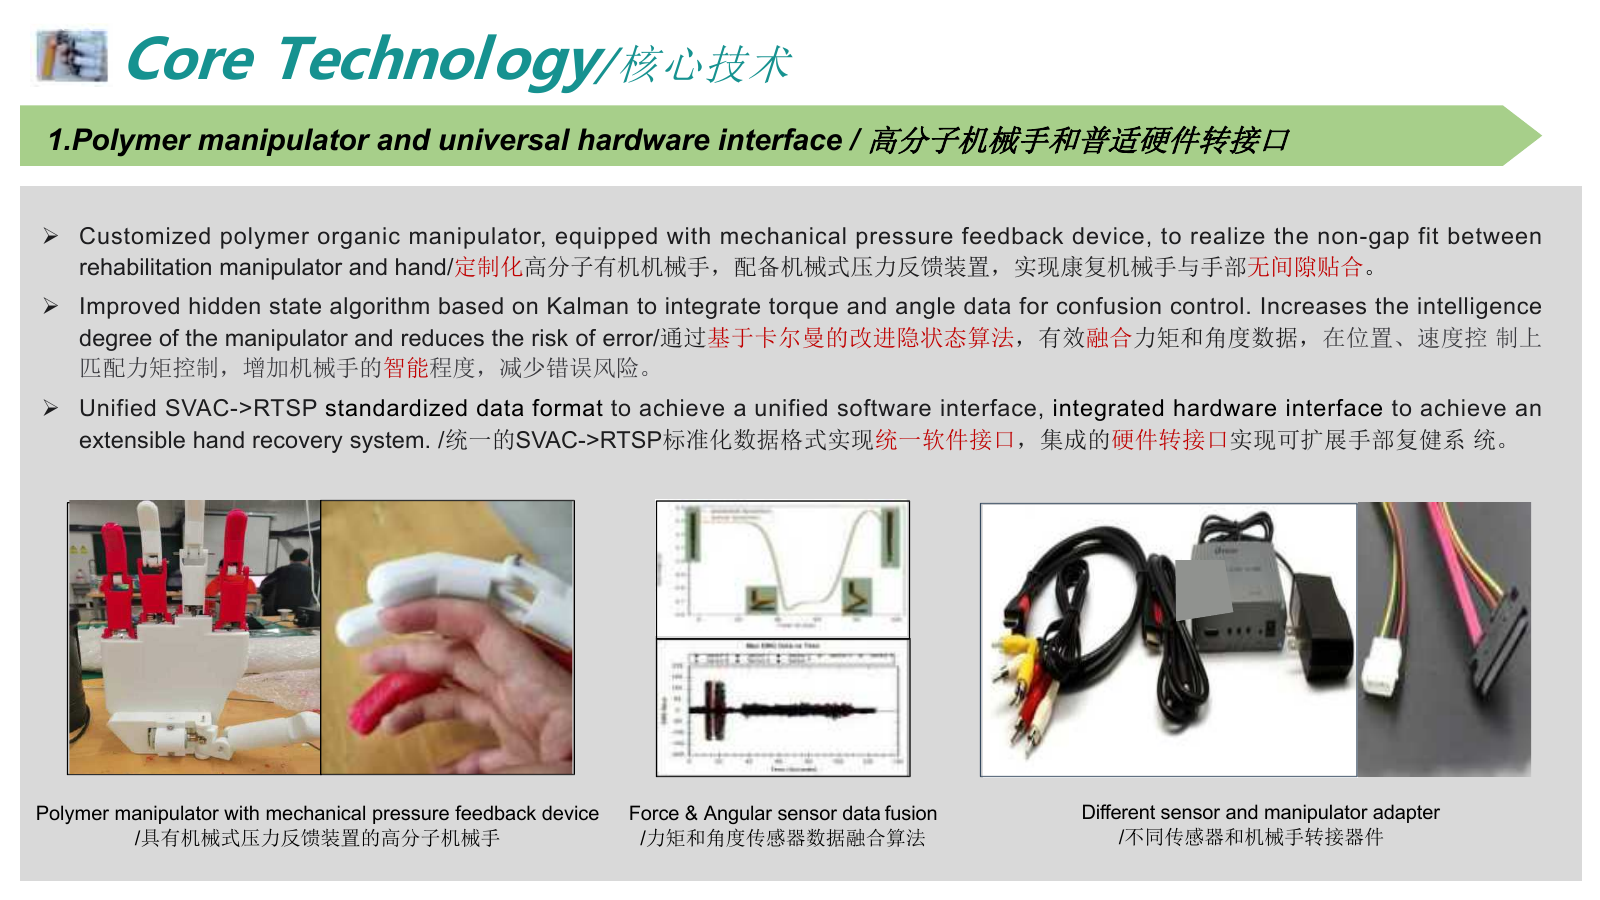
- The core technical idea combines polymer organic manipulators, a universal hardware interface, mechanical pressure feedback, and force-angle sensor data fusion.
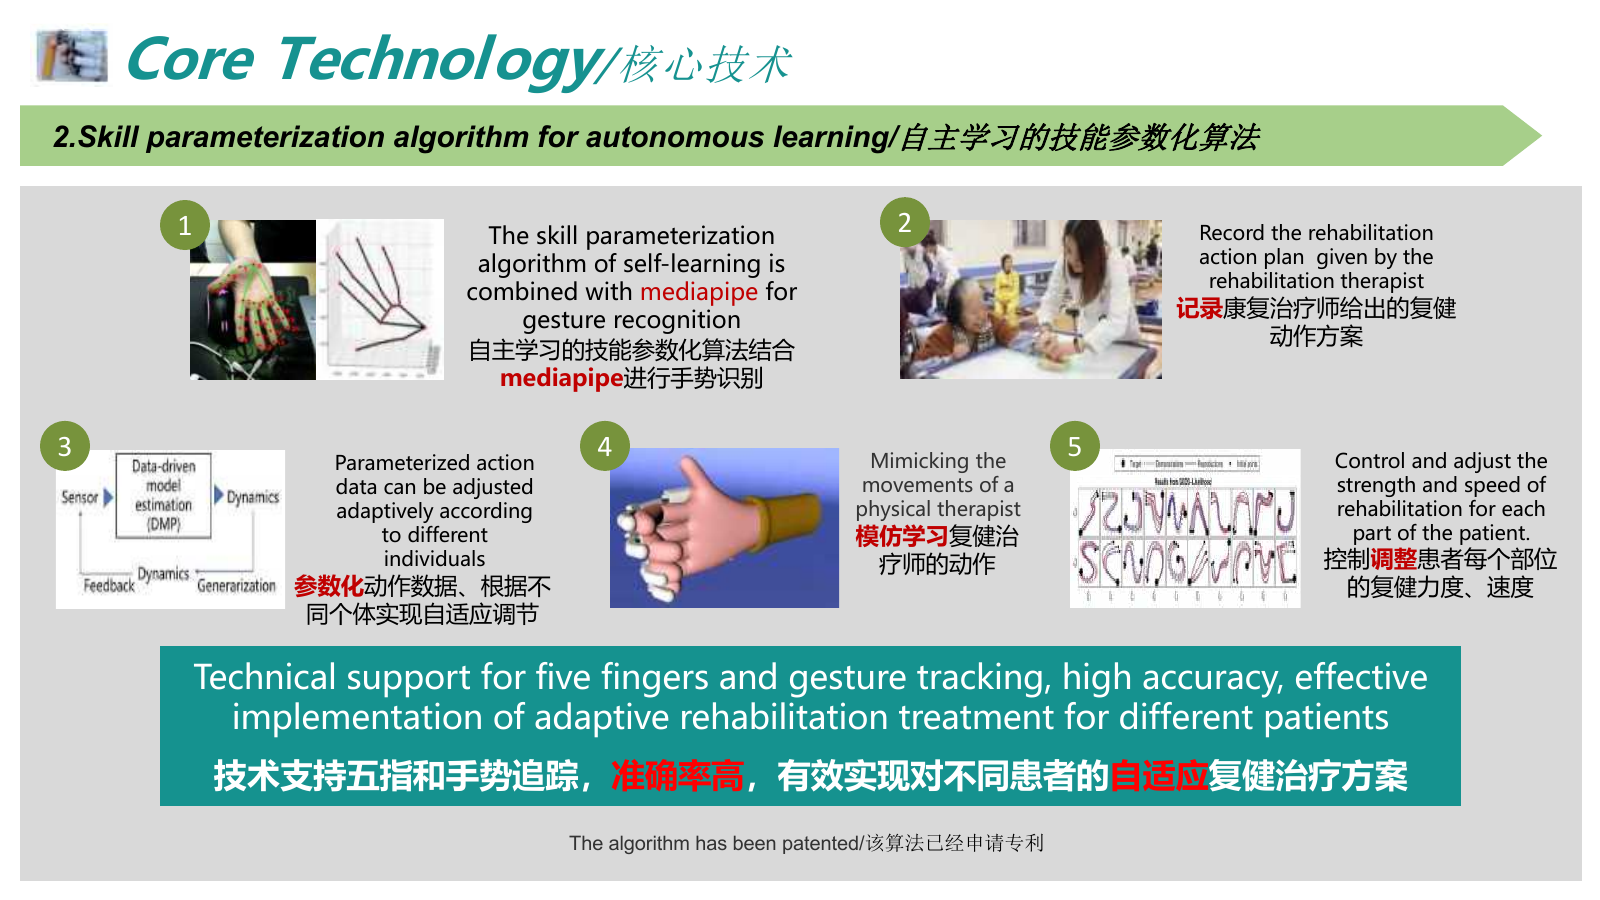
- A parameterized imitation-learning method is proposed to learn therapist operations from samples and adjust rehabilitation motion range for individual patients.
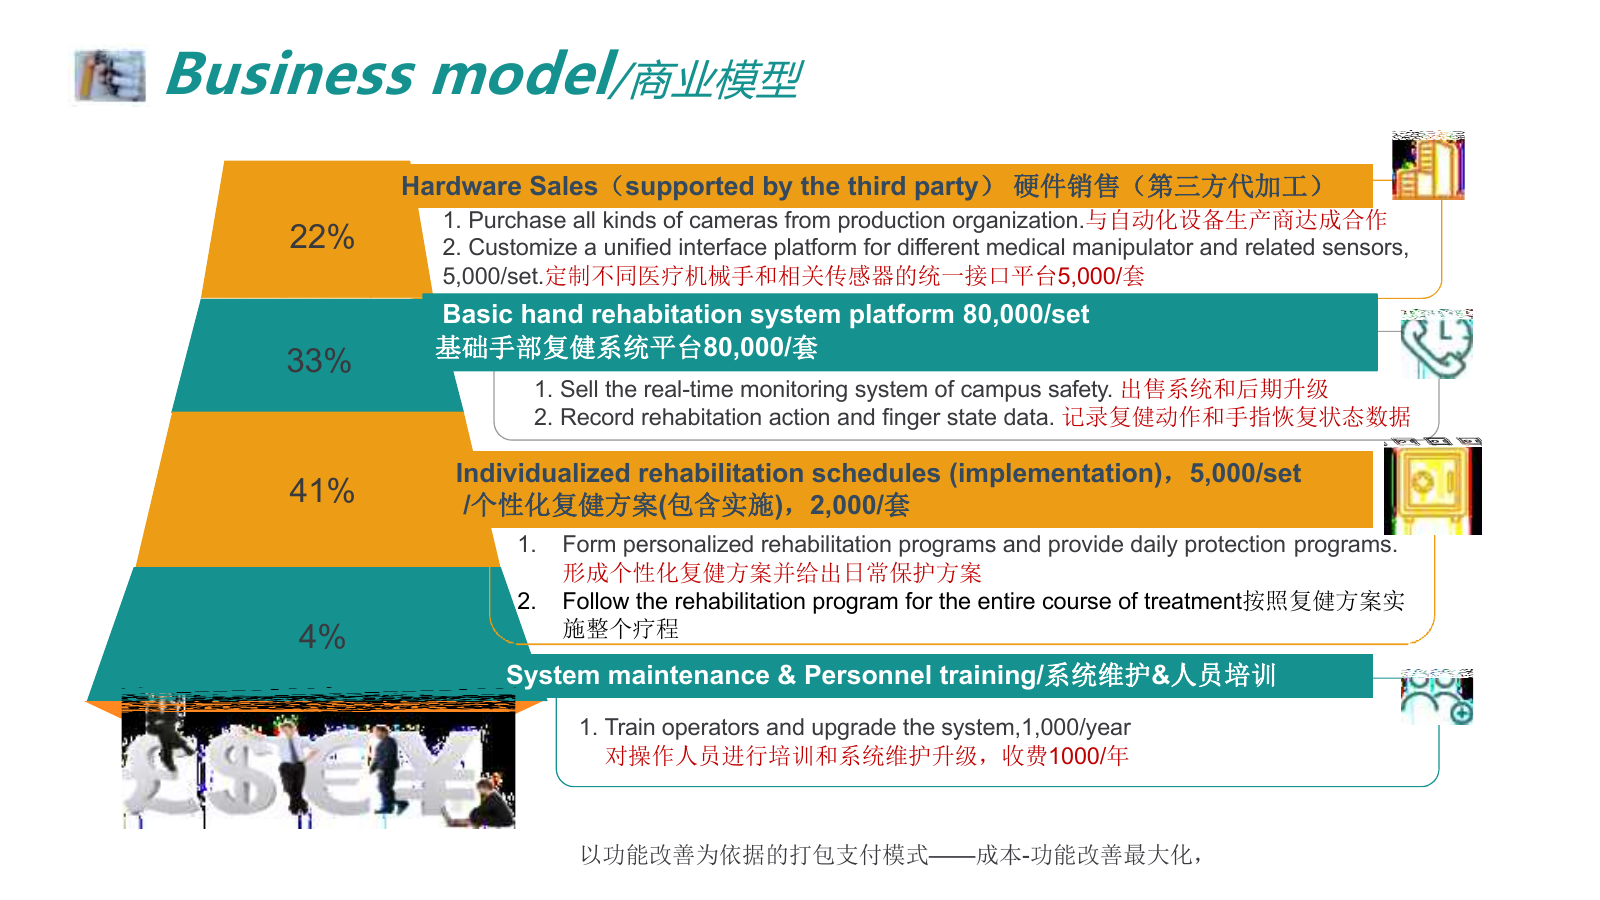
- The project also includes market analysis, patent status, cooperation intentions, business model planning and staged development targets; it should be shown as an innovation project rather than a clinically validated medical device.
Gallery